Nantes France
B.Sc. Electronics Engineering · Nantes Université
Four years of electronics engineering. The first island, and the pad this flight takes off from.
- Electronics
- 2014–2018
 Flight log · 2014 to now
Head of Robotics at SIRB.AI, Abu Dhabi. Eight years in robotics, from a virtual microcontroller to drone swarms. Here is the route, place by place. You fly it.
Scroll to throttleMove to steerHold Space to cruise
Swipe up to throttleDrag sideways to steer
B.Sc. Electronics Engineering · Nantes Université
Four years of electronics engineering. The first island, and the pad this flight takes off from.
Embedded Software Engineer · Hiventive
Built a SystemC/TLM virtual prototype of an STM32 microcontroller, with QEMU integration. Lesson kept: treat time, memory and bandwidth as a budget, and test against a model of the hardware first.
Robotics Assistant · Ingeniarius
Built full autonomy stacks from scratch, with ROS and embedded systems. Won both maze-solving competitions: the mapped one and the unmapped one.
M.Sc. Control & Robotics, then Robotics Researcher · Ecole Centrale de Nantes
Led 4 research projects: multi-agent pathfinding, AI planning (PDDL), real-time ROS control on Xenomai/XDDP, and ROS 2 latency benchmarking. In parallel, remote for Hiventive: backend services in Go.
Founding Robotics Engineer · Coalescent Mobile Robotics
Founding team that delivered the first working in-store robot, in a supermarket. Led navigation, then,
after the CTO left, trolley detection, planning and training interns and a junior engineer.
A real store changes your priorities fast.
Senior Engineer, Robotics Software · Technology Innovation Institute
Led R&D for multi-robot orchestration and control, and designed new swarm behaviours, including decentralized bird-inspired flocking. Live demos to partners led to USD 3M in contracts.
Team Lead, Robotics Software · TII
Grew and led a team of 9 engineers, overhauled the swarm autonomy architecture and worked with Caltech on M4, their flying and rolling robot. Demos in Europe and the UAE led to USD 10M+ in contracts.
Head of Robotics · founding team
Designed the robotics architecture and a self-healing autonomy layer, with agents that detect and recover from failures across the swarm. Took it from prototype to public launch at UMEX 2026, as the Middle East's first AI-powered swarm platform.
Pilot's licence
Head of Robotics, SIRB.AI. Leads robotics software teams across orchestration, navigation and fault management.
Hangar
Eight projects, each with a short clip. Every change goes draft → AI review → checks → quiz → human review → ship, whoever or whatever wrote it. grip is that quiz, as a hook.
Bay 04
Graph-based agent orchestration: a spoken intent becomes a queue of build jobs, run by local-first agents.
Paperwork
Postcards
My own photos, from trips to California and the US West, Paris, Togo and the Maldives.
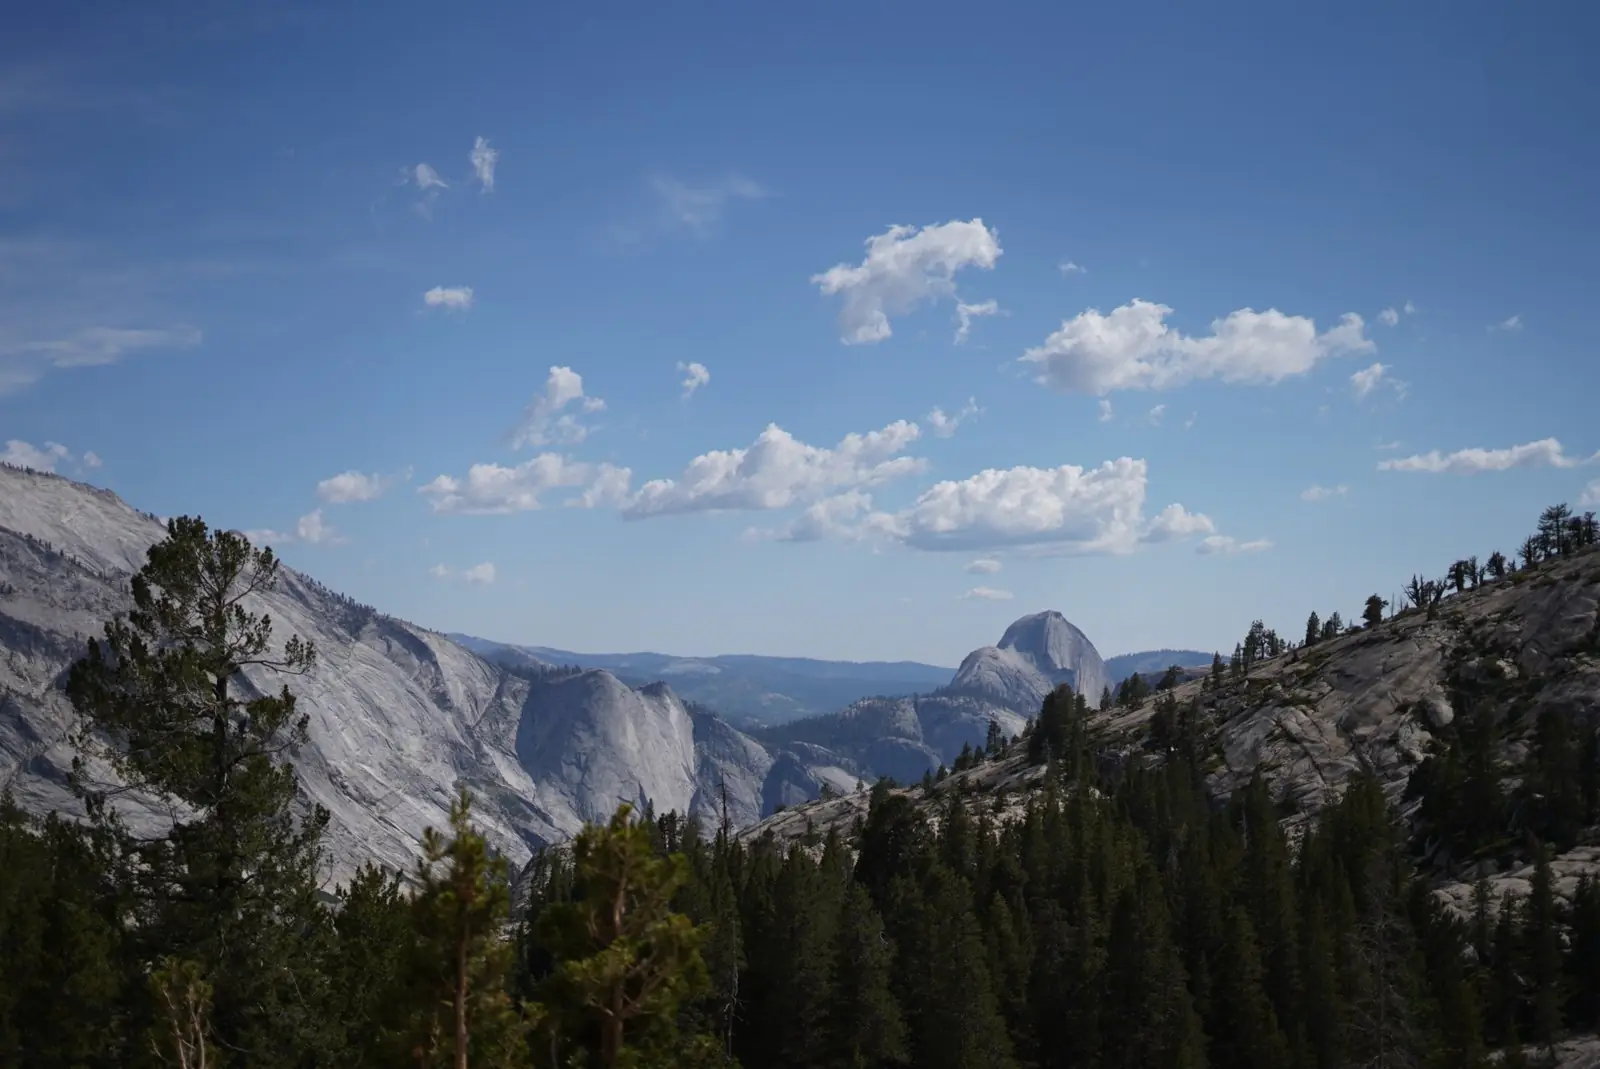
Yosemite California
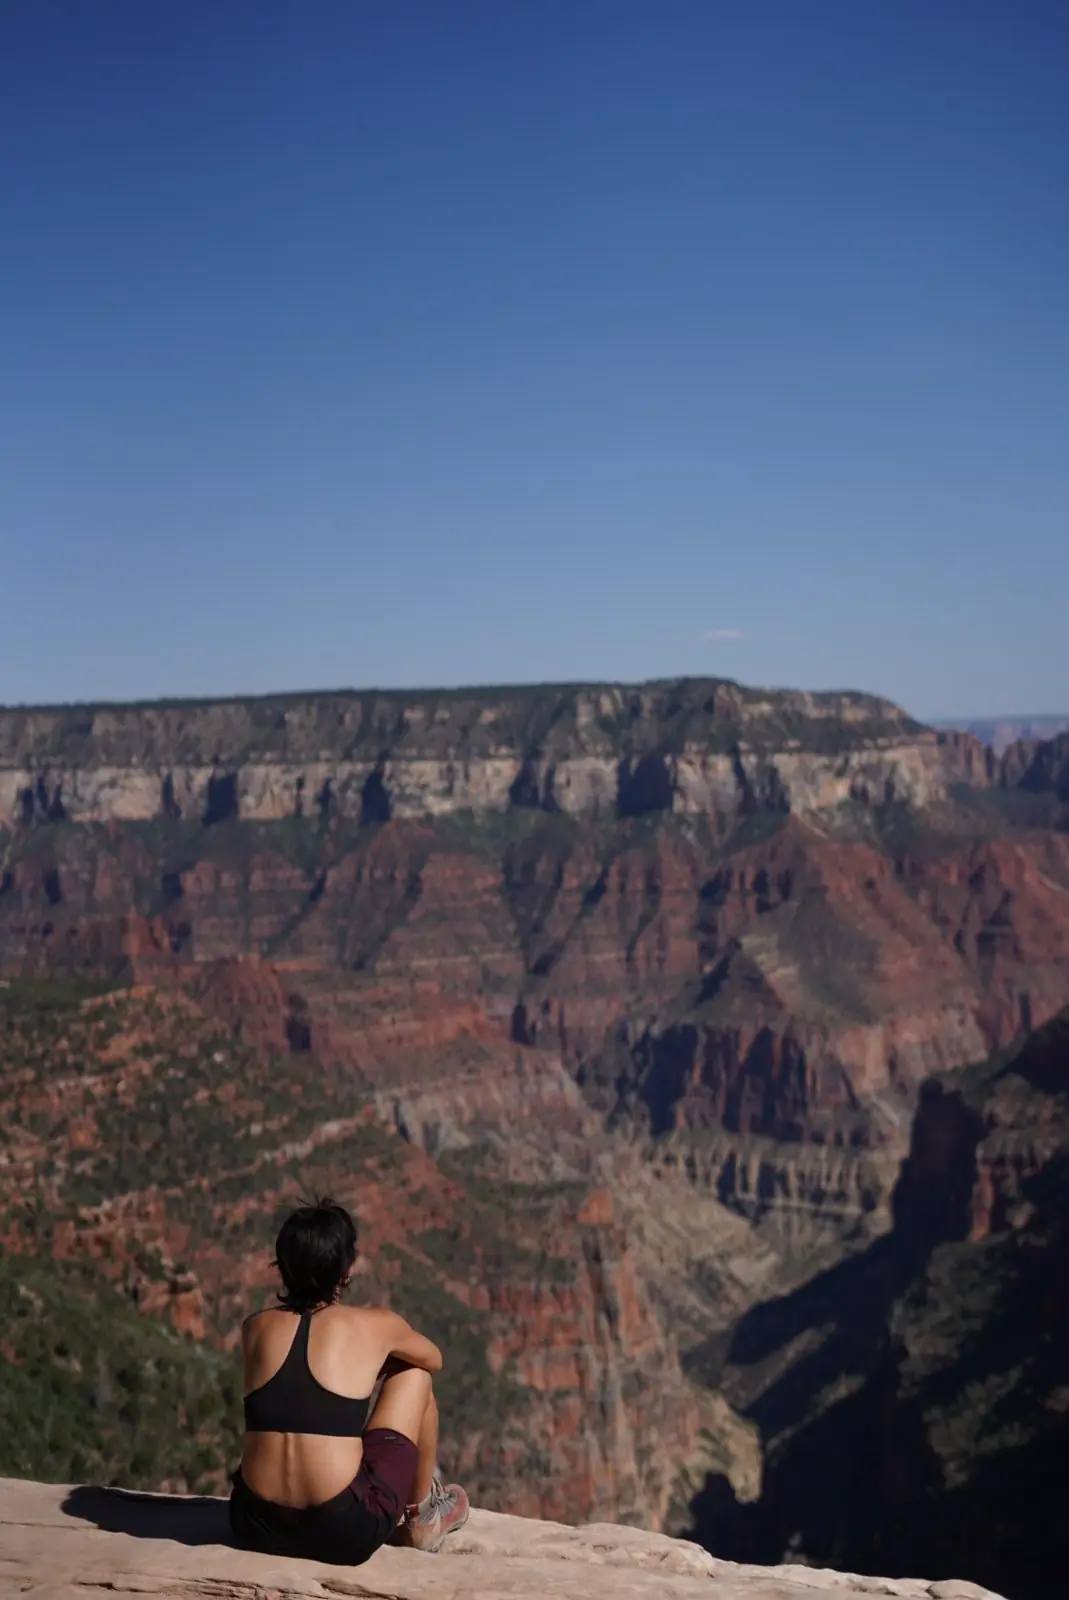
Grand Canyon USA
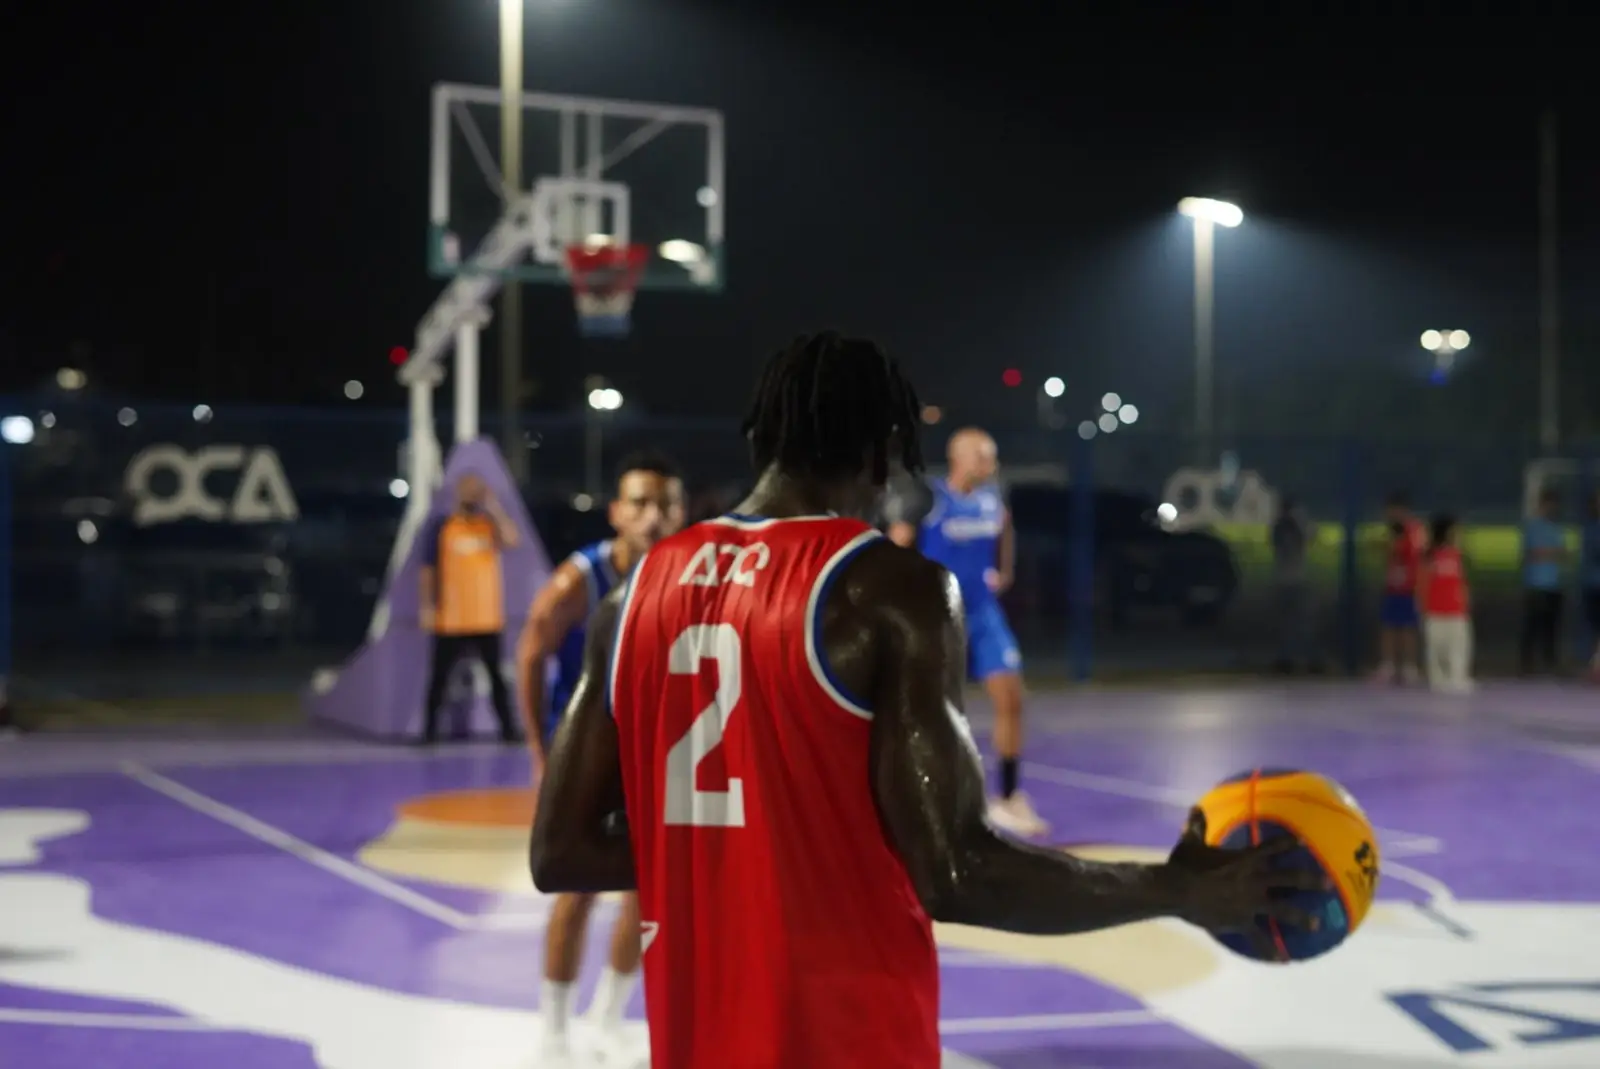
Clinton ball USA
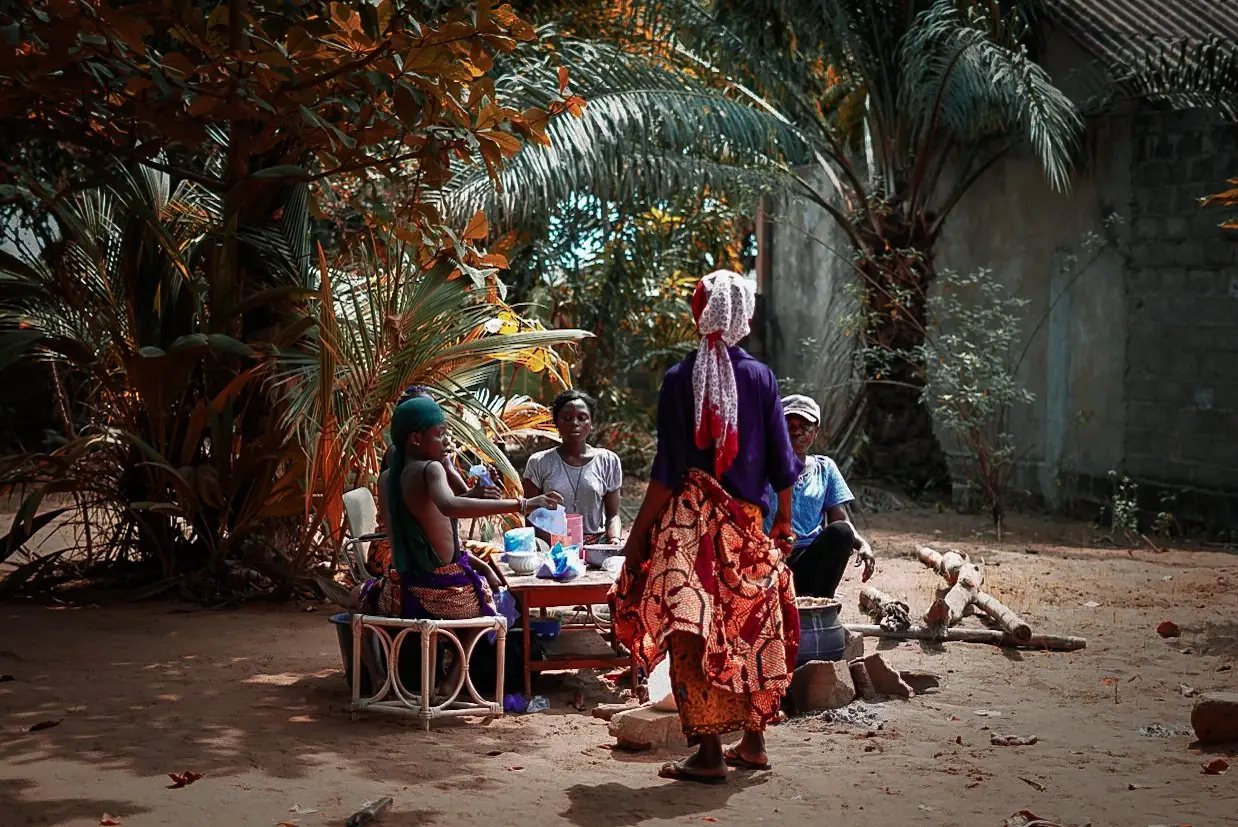
Cooking, in colour Togo
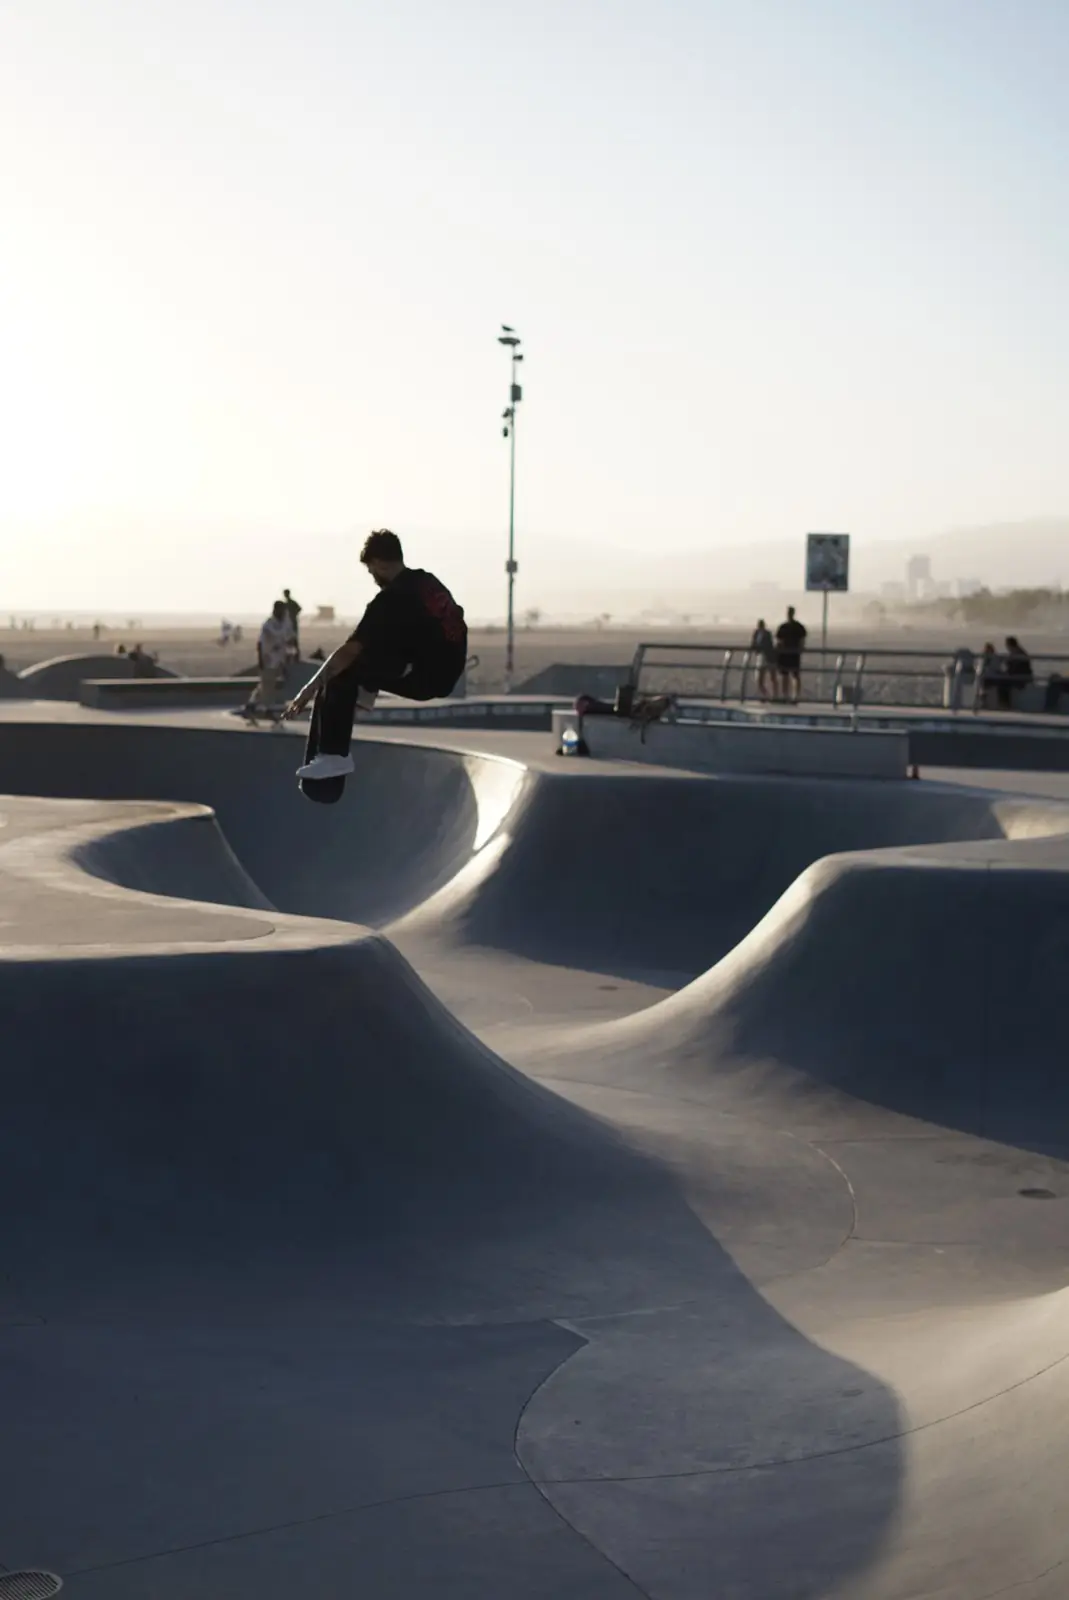
Skating Santa Monica
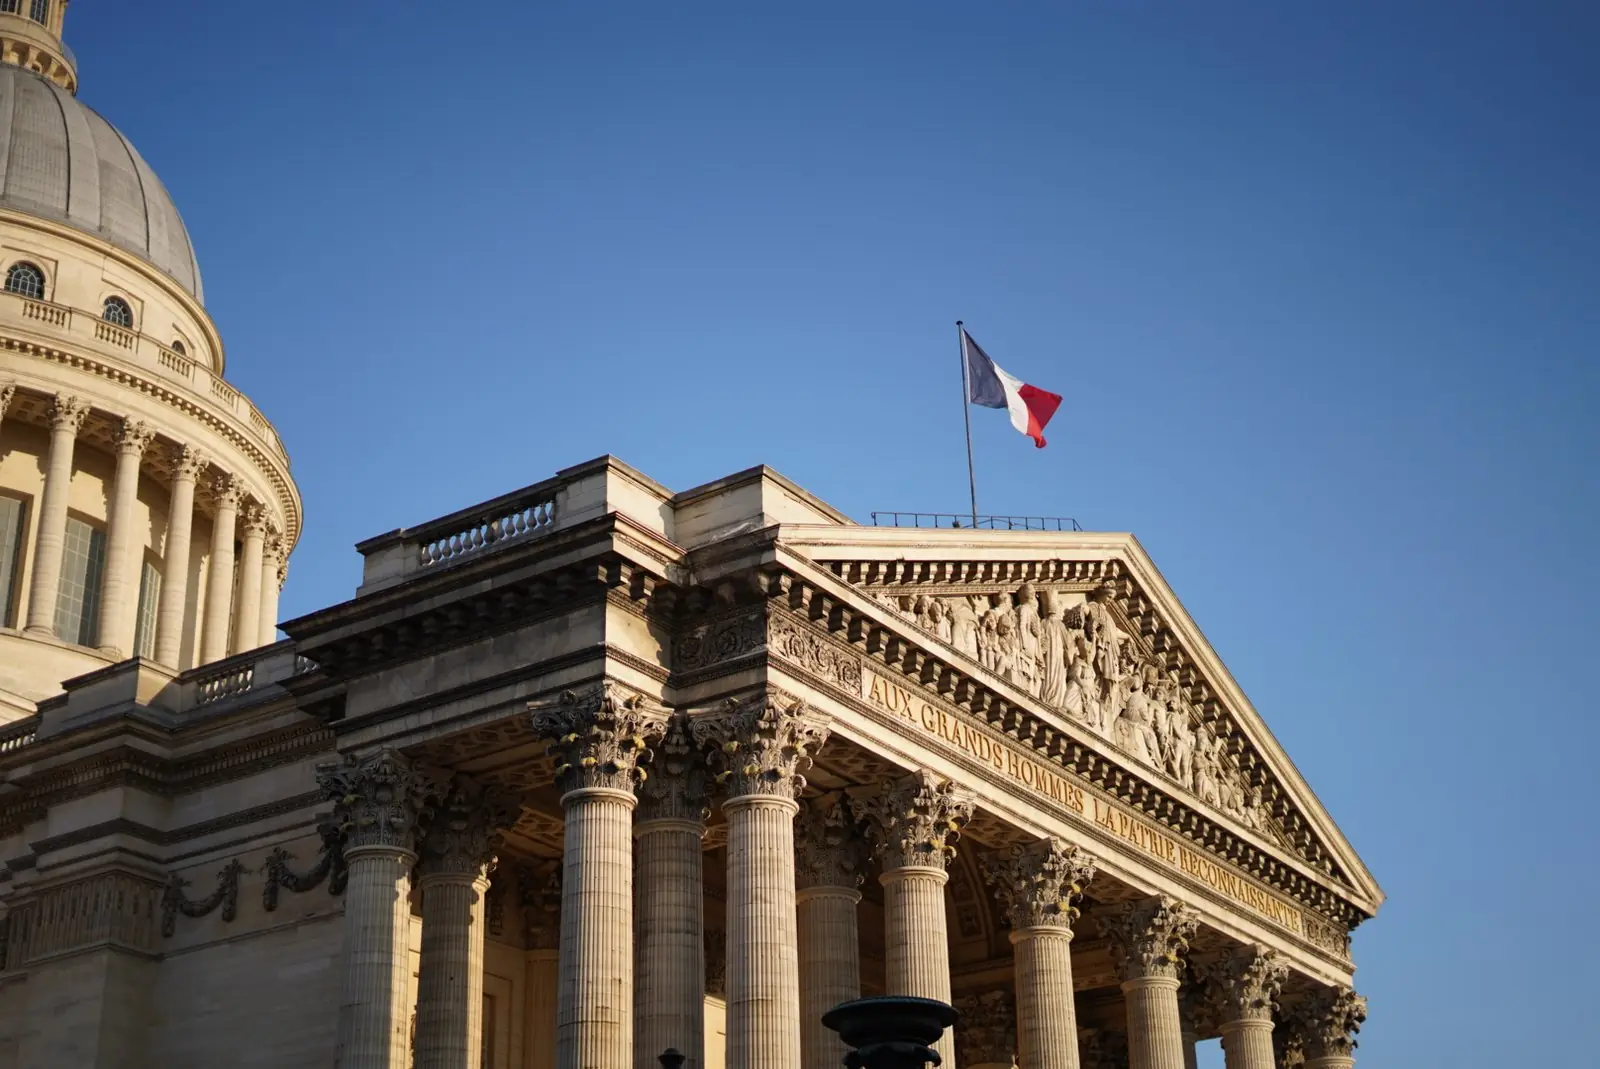
Monument Paris
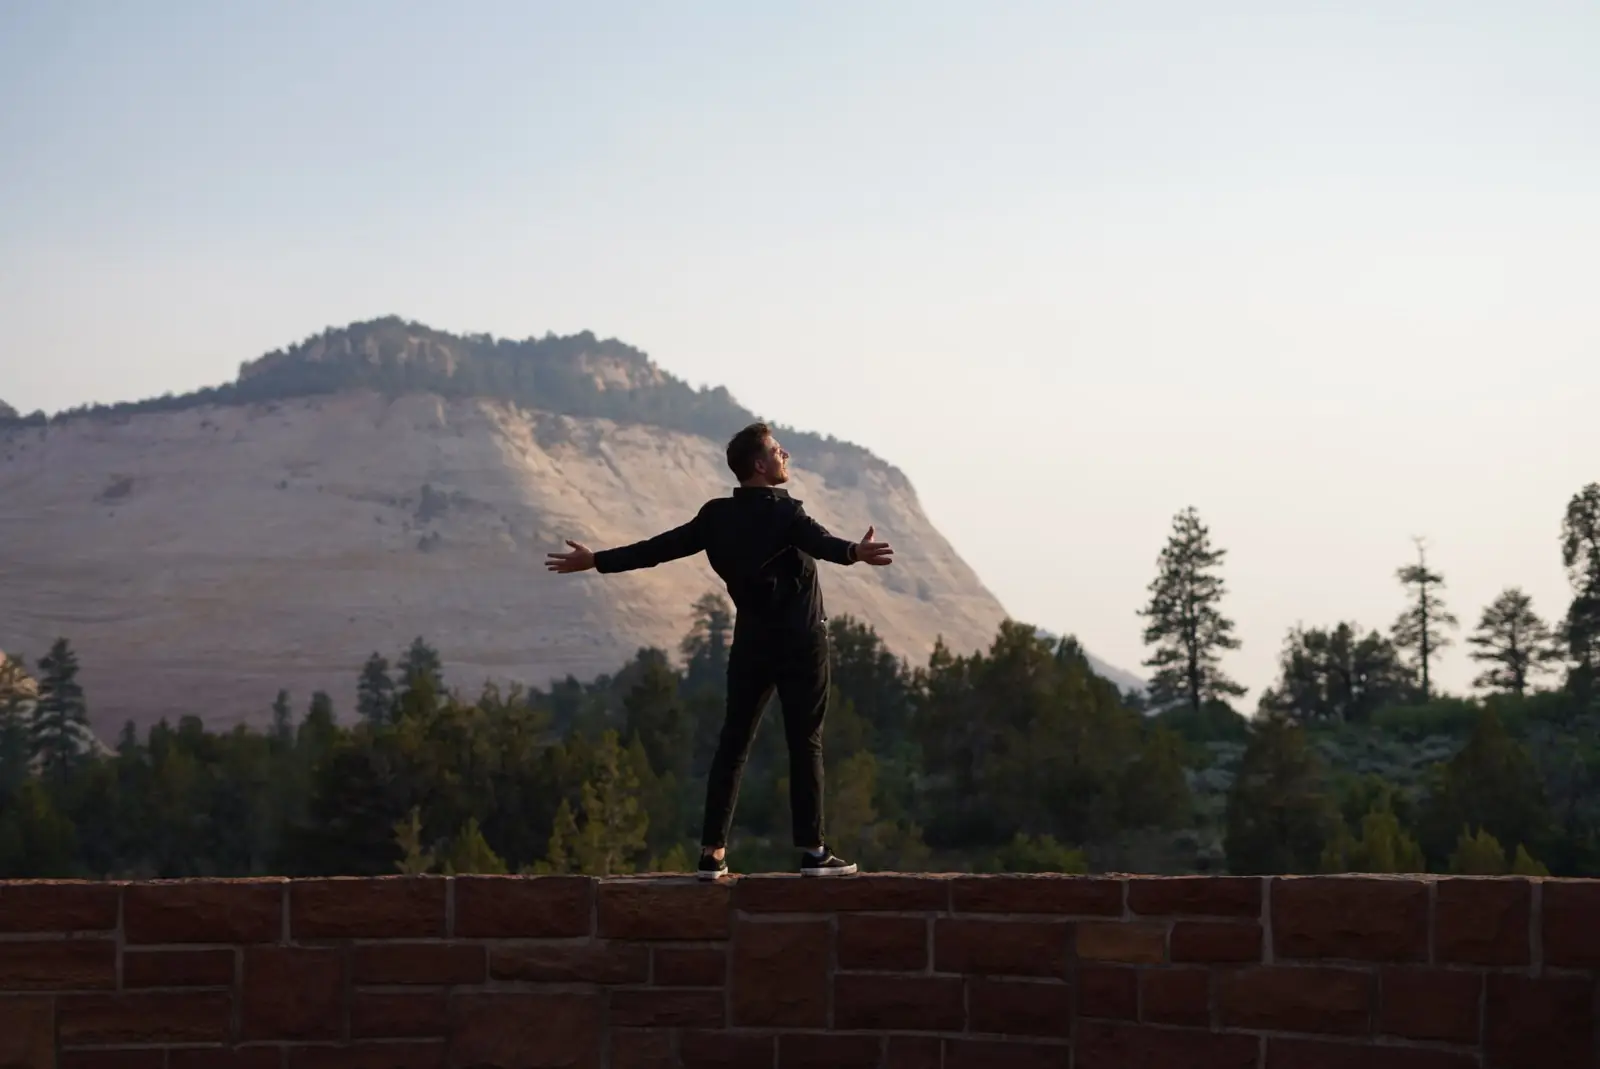
Pavel, happy Zion
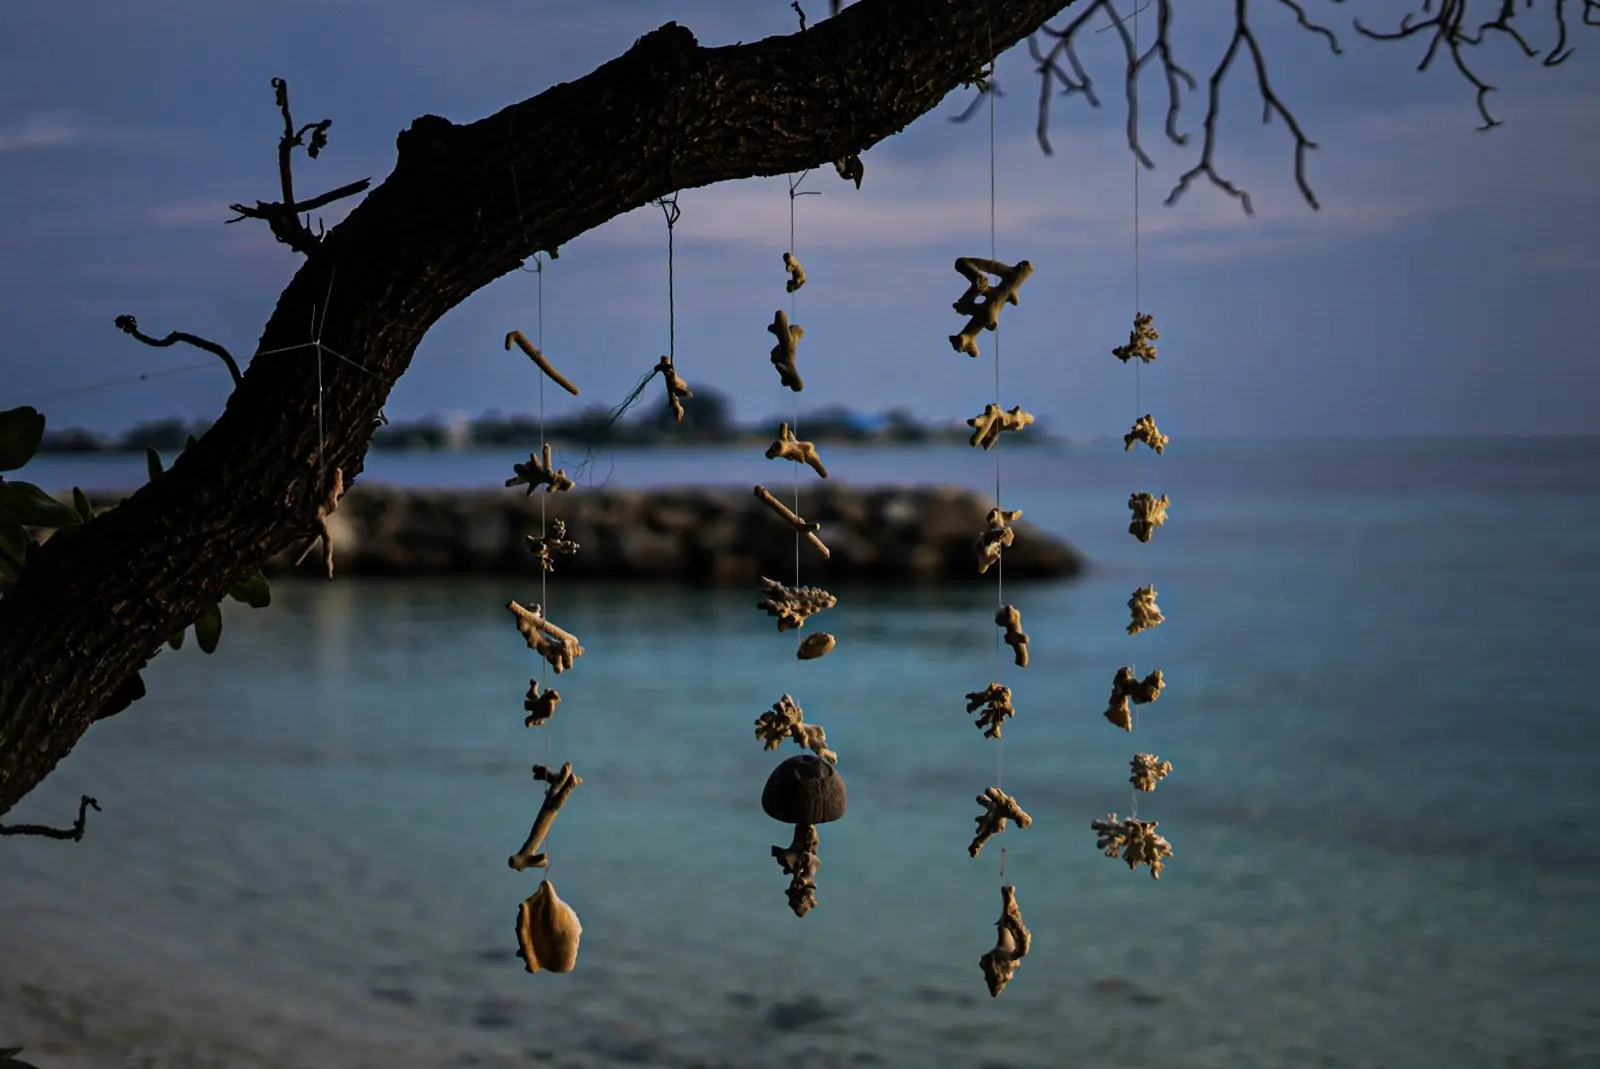
Hanging shells Maldives
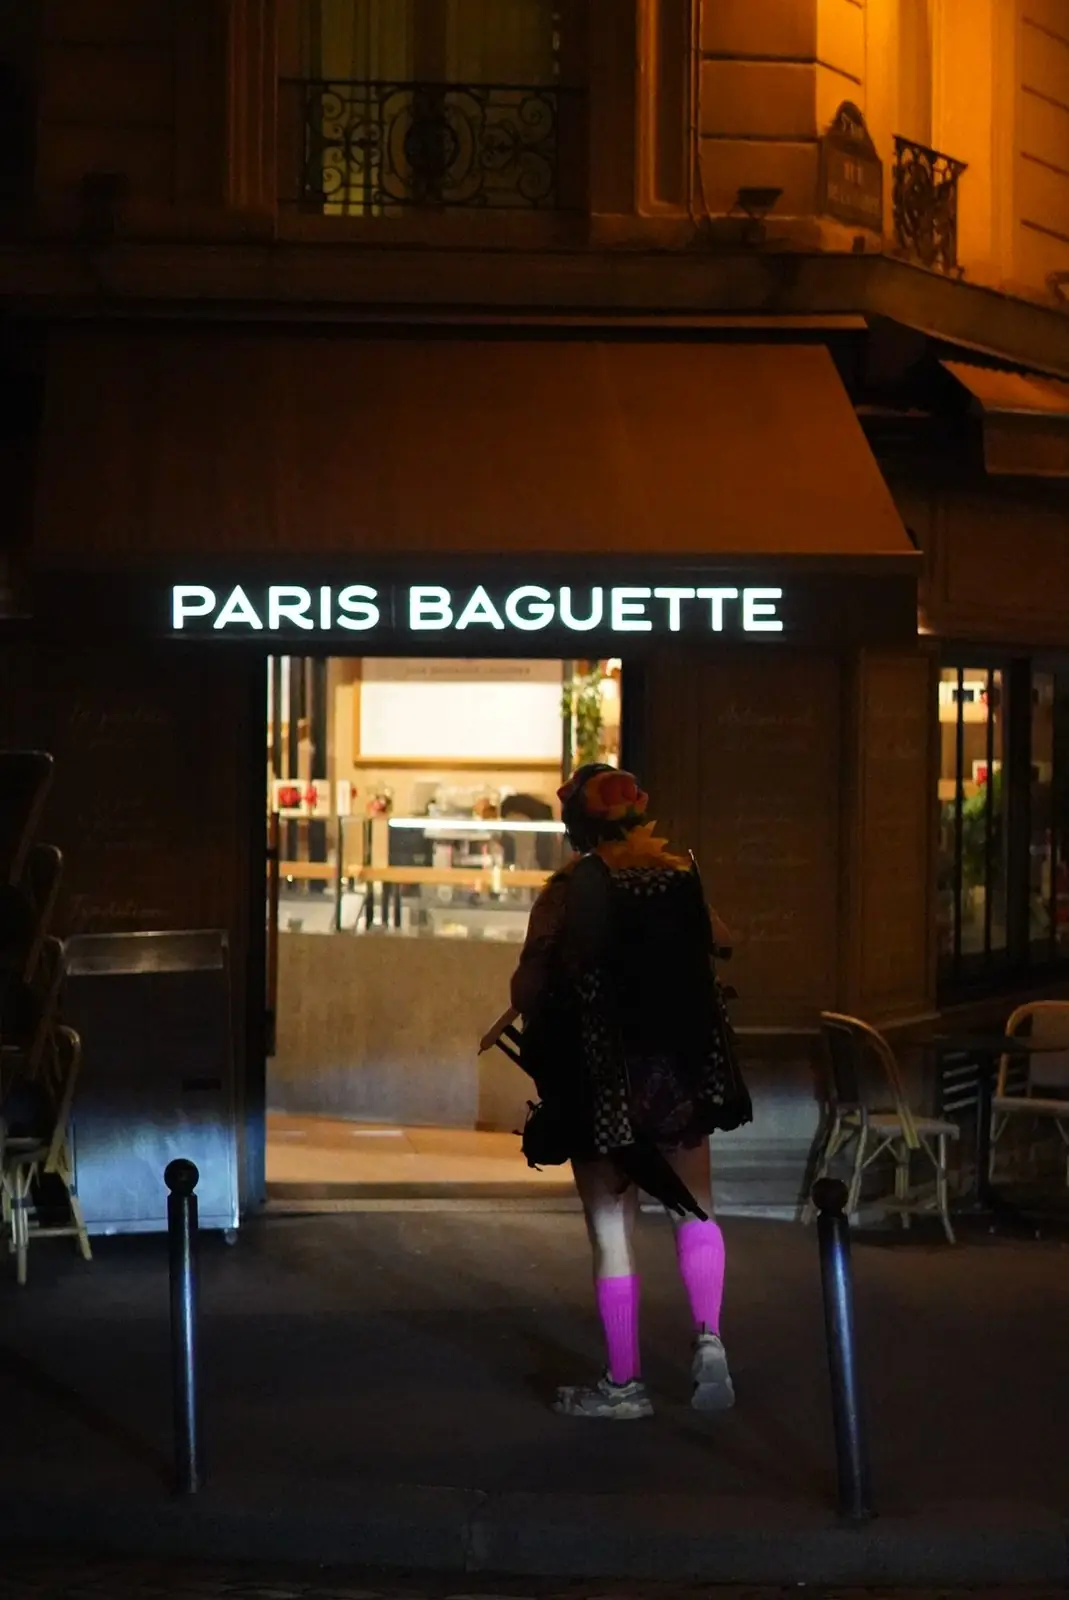
Paris Baguette Paris
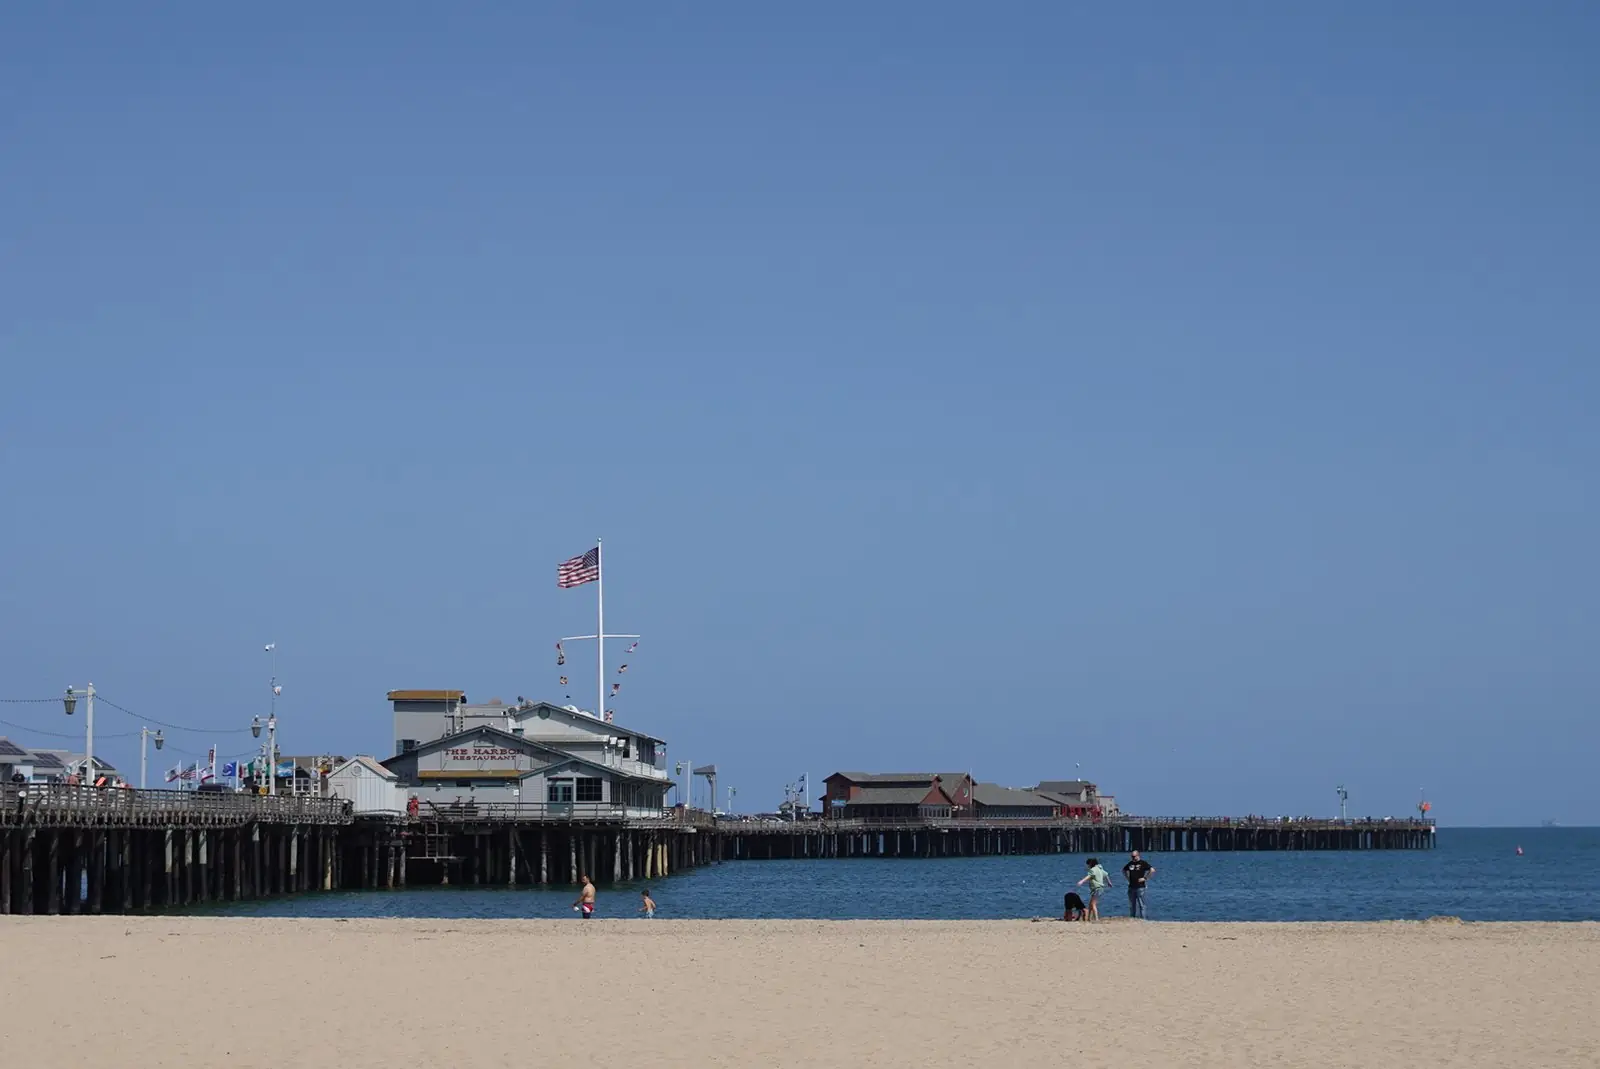
The pier Santa Barbara
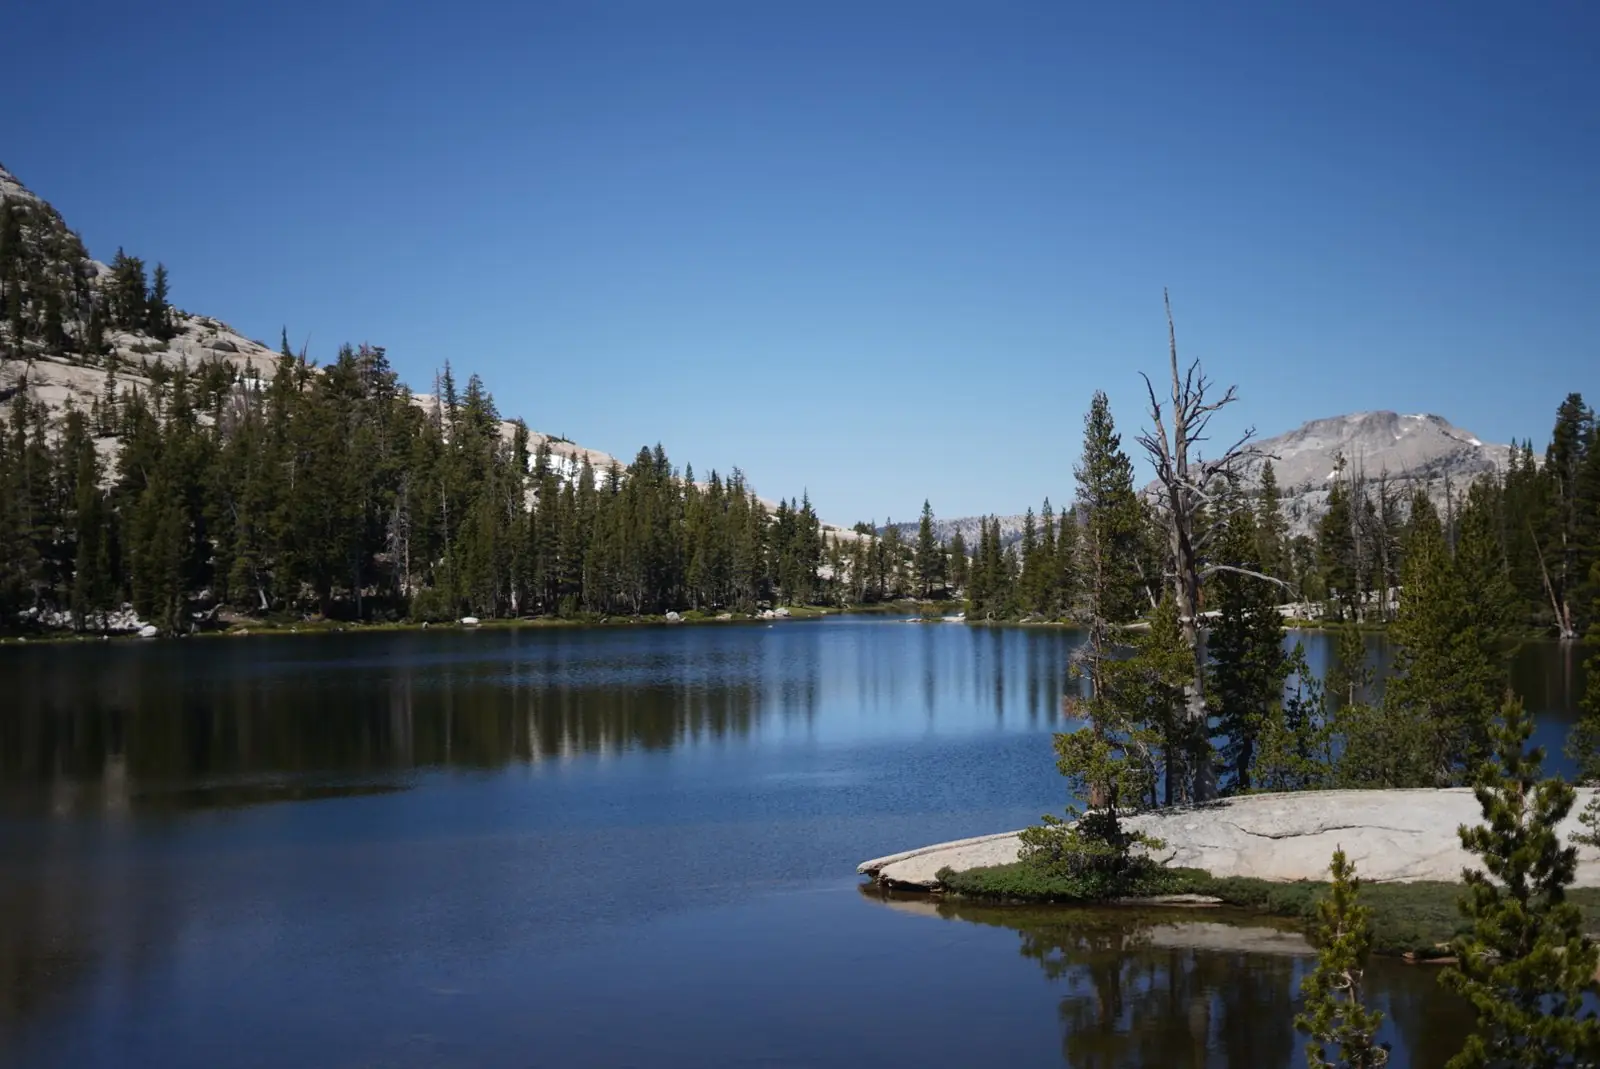
Cathedral Lakes USA
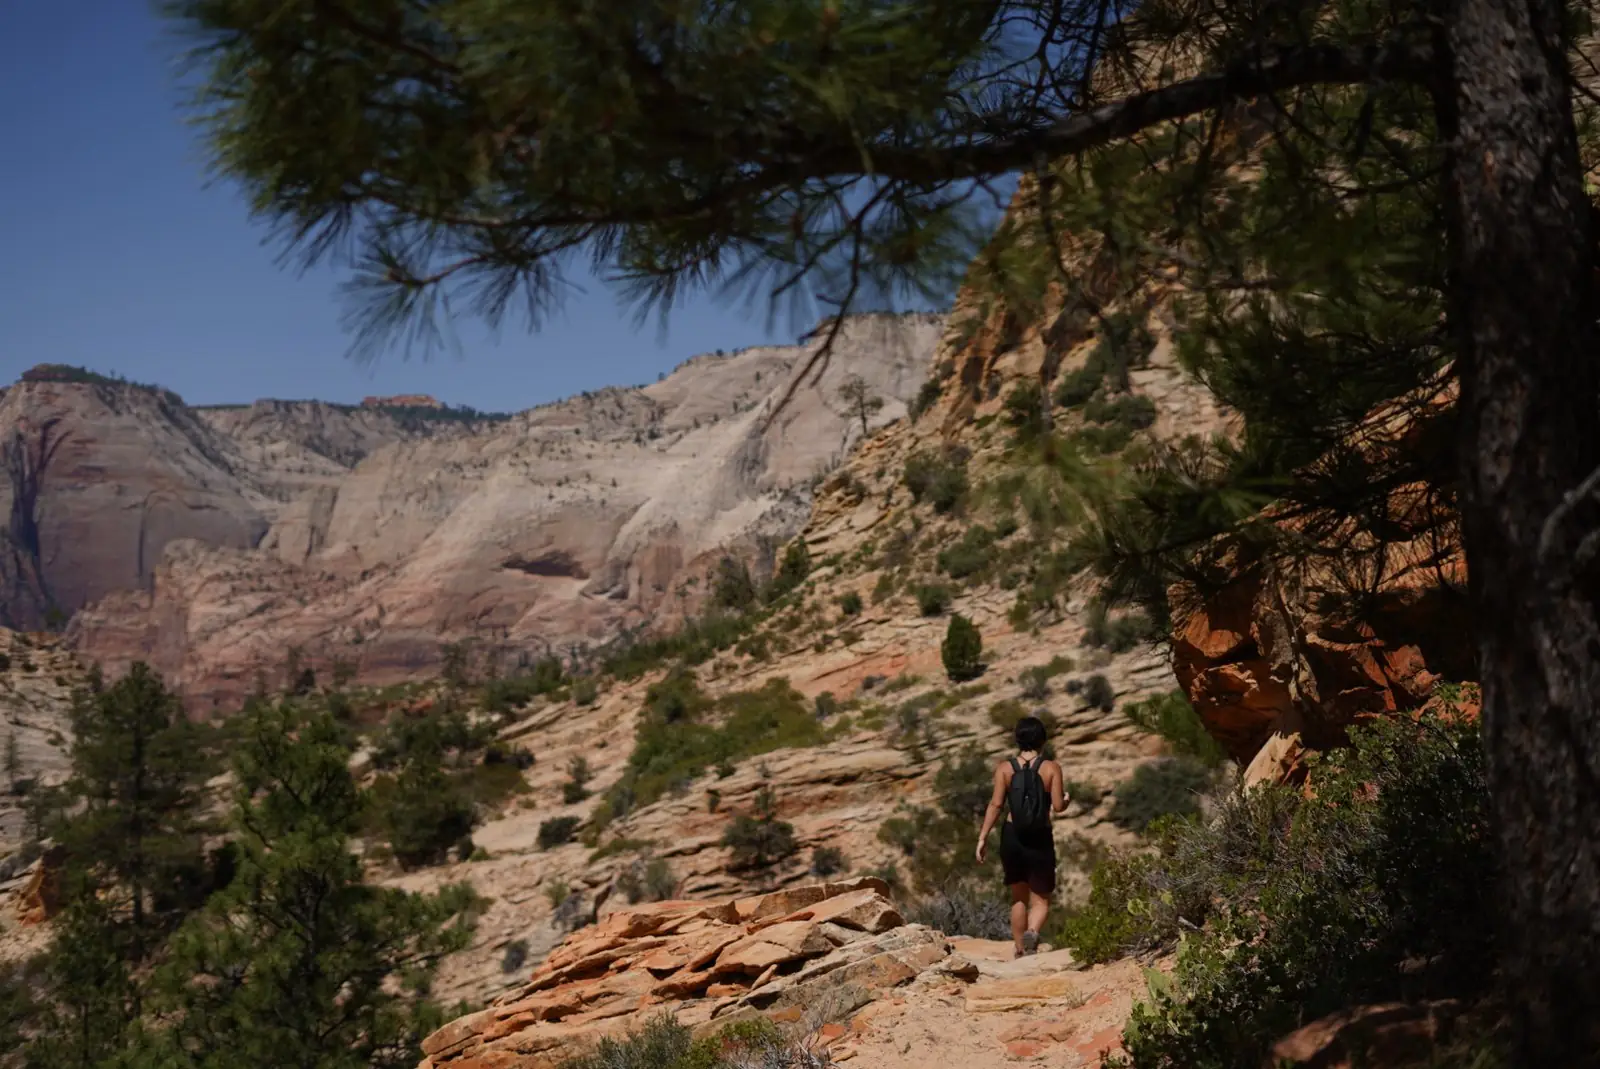
Zion trail Zion
Radio
Swarms, multi-agent planning, robot autonomy, or one of the projects above: write to me.